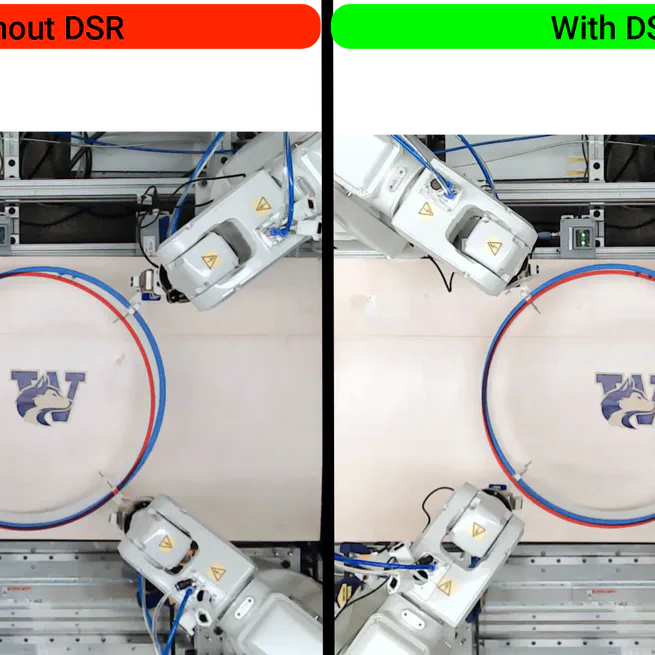
Delayed Self-Reinforcement to Reduce Deformation During Decentralized Flexible-Object Transport
Introduces delayed self-reinforcement (DSR), where each robot reinforces its actions using information it already has, to reduce object deformation during decentralized transport without increasing transport time or adding communication. Experiments show deformation reduced by at least 72% compared with the case without DSR.
Dec 1, 2024
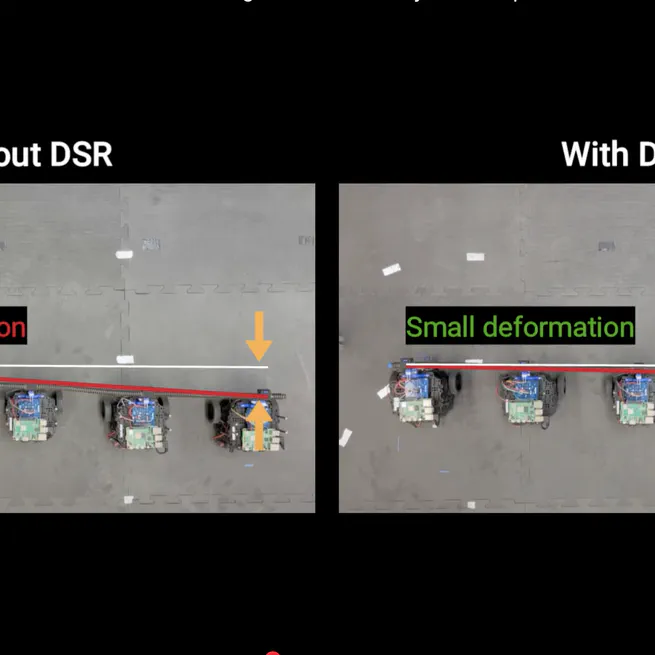
Communication-Free Decentralized Controller Design for Flexible Object Transport
A decentralized way to choose controller parameters for robot teams transporting objects, using only local measurements and the desired network performance, with no prior knowledge of the network or object. Experiments show the DSR approach reduces deformation by 66% with mobile robots and 57% with industrial robots.
Jun 4, 2024

Data-Based Stiffness Estimation for Control of Robot–Workpiece Elastic Interactions
A model-free, data-based algorithm that learns the combined robot–workpiece stiffness and uses it to apply desired forces and torques when clamping or drilling elastic structures. Experiments show clamping speed increased four times while interaction forces stayed within acceptable bounds.
Jul 1, 2023
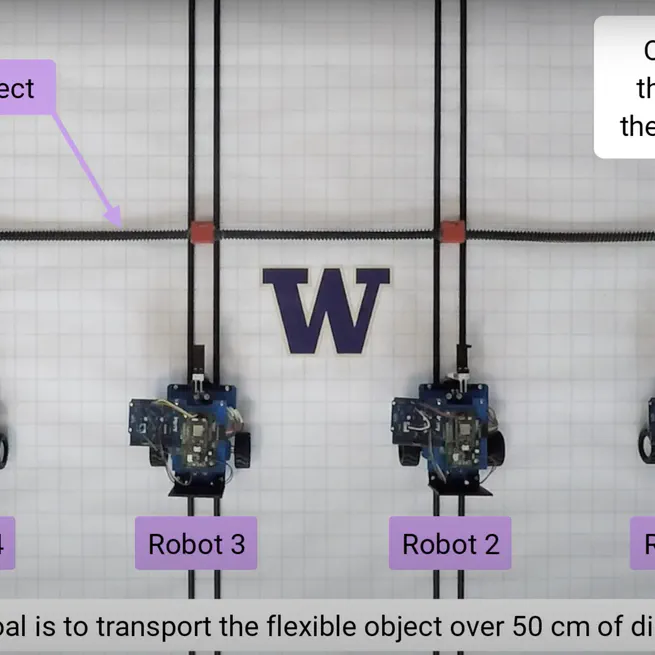
Accelerated-Gradient-Based Flexible-Object Transport With Decentralized Robot Teams
An accelerated-gradient approach (A-DSR) for transporting flexible objects faster with a decentralized robot team, using only local force sensing and no inter-robot communication. Experiments show 60% less deformation for the same transport time, or 59% shorter transport time for the same deformation.
Nov 6, 2020

Data-Based Learning for Control of Elastic Interactions Between Robot and Workpiece
Shows experimentally that data collected during a robotic clamping operation can be used to speed up similar operations on flexible structures. Using the learned robot–workpiece relationship, operating speed was increased three times while keeping interaction forces and torques within acceptable levels.
Oct 8, 2019